Policy Studio early access
imit8-studio v0.2.0-alpha4 — the Phase 1 retargeting layer, perception pipeline scaffolding, evaluation harness, and a six-page operator browser dashboard, now bundled with the LeRobot NexArm fork and URDF so the read from arm button works from the tarball alone. Shipped under an early-access licence to invited design partners.
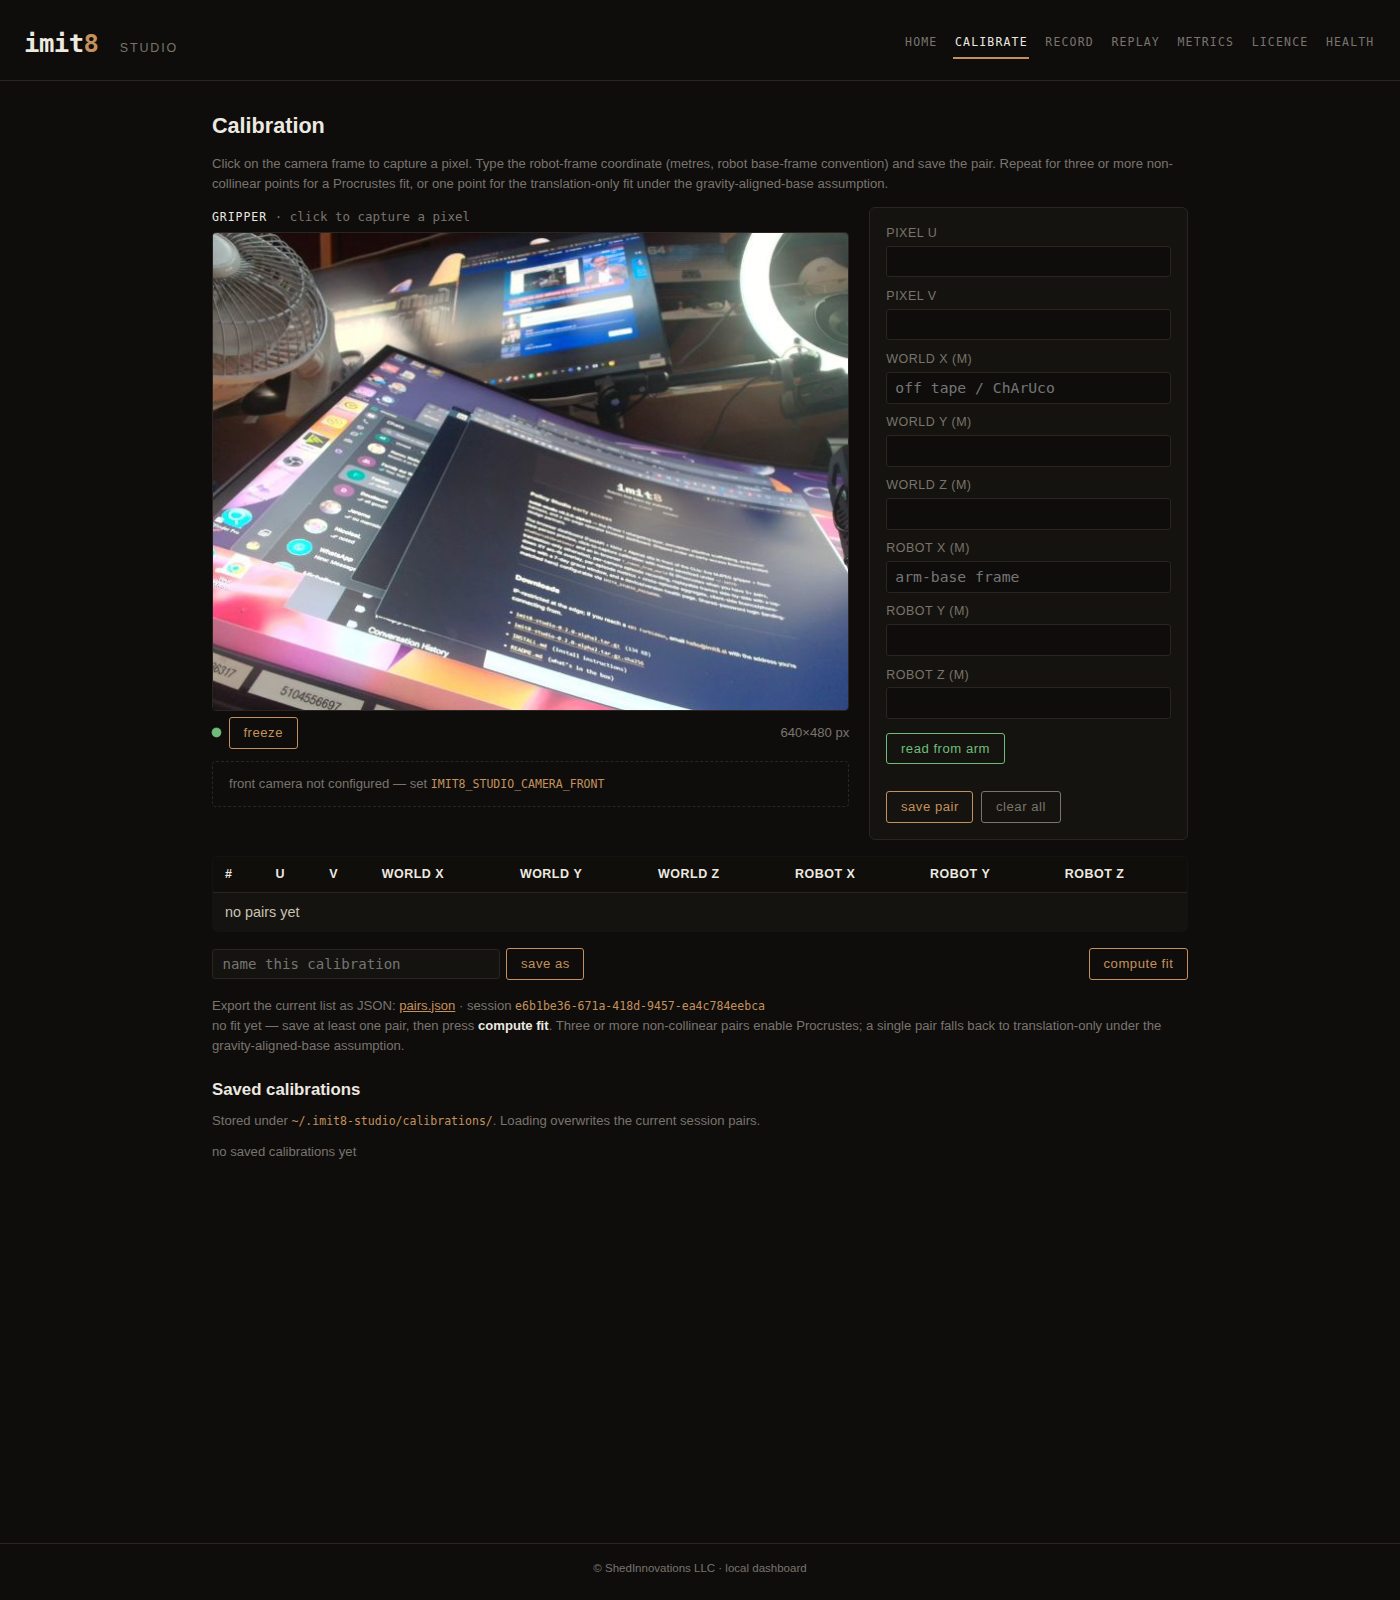
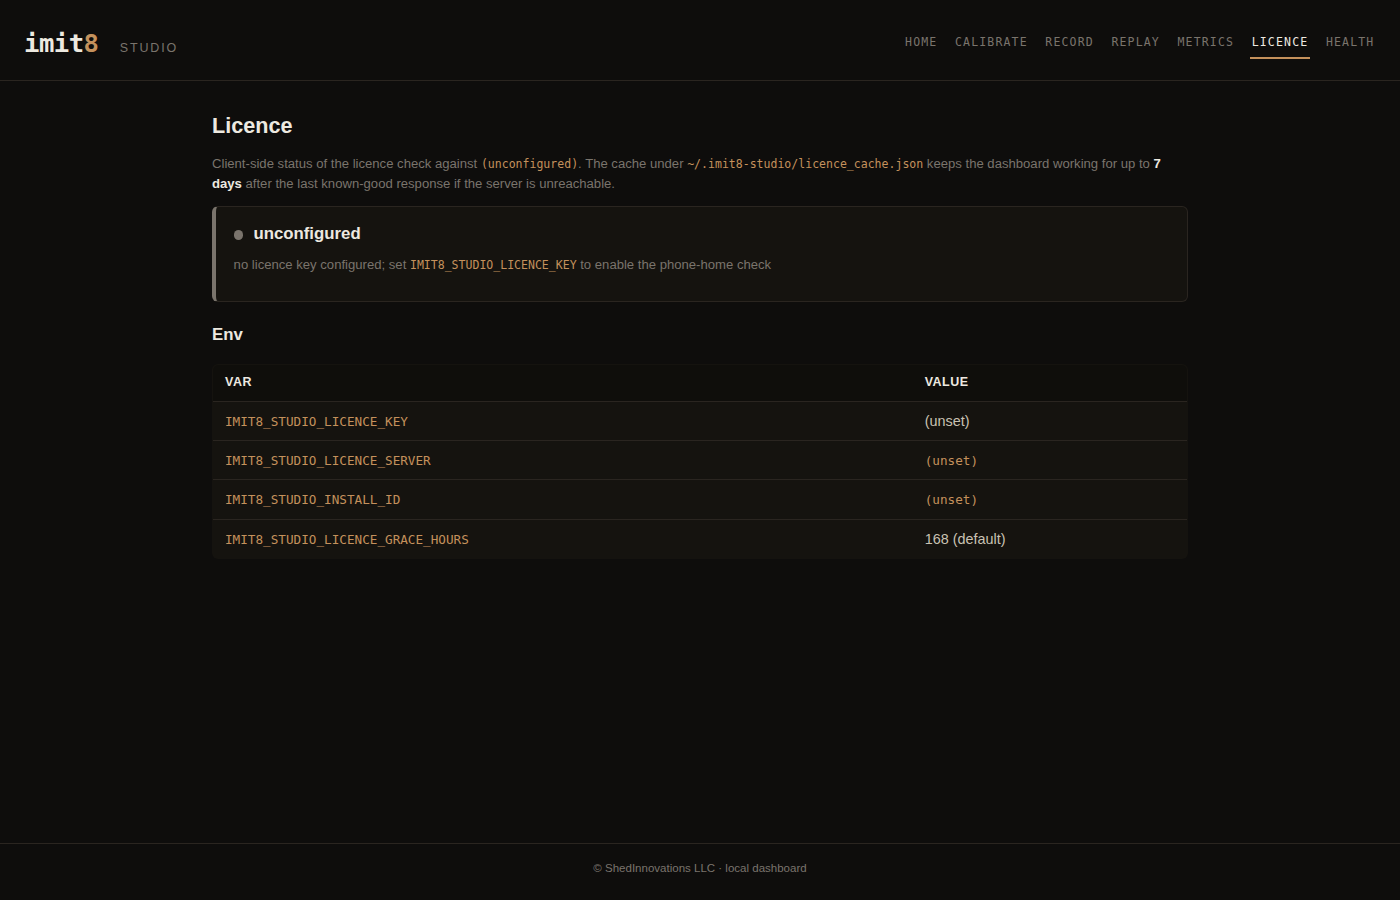
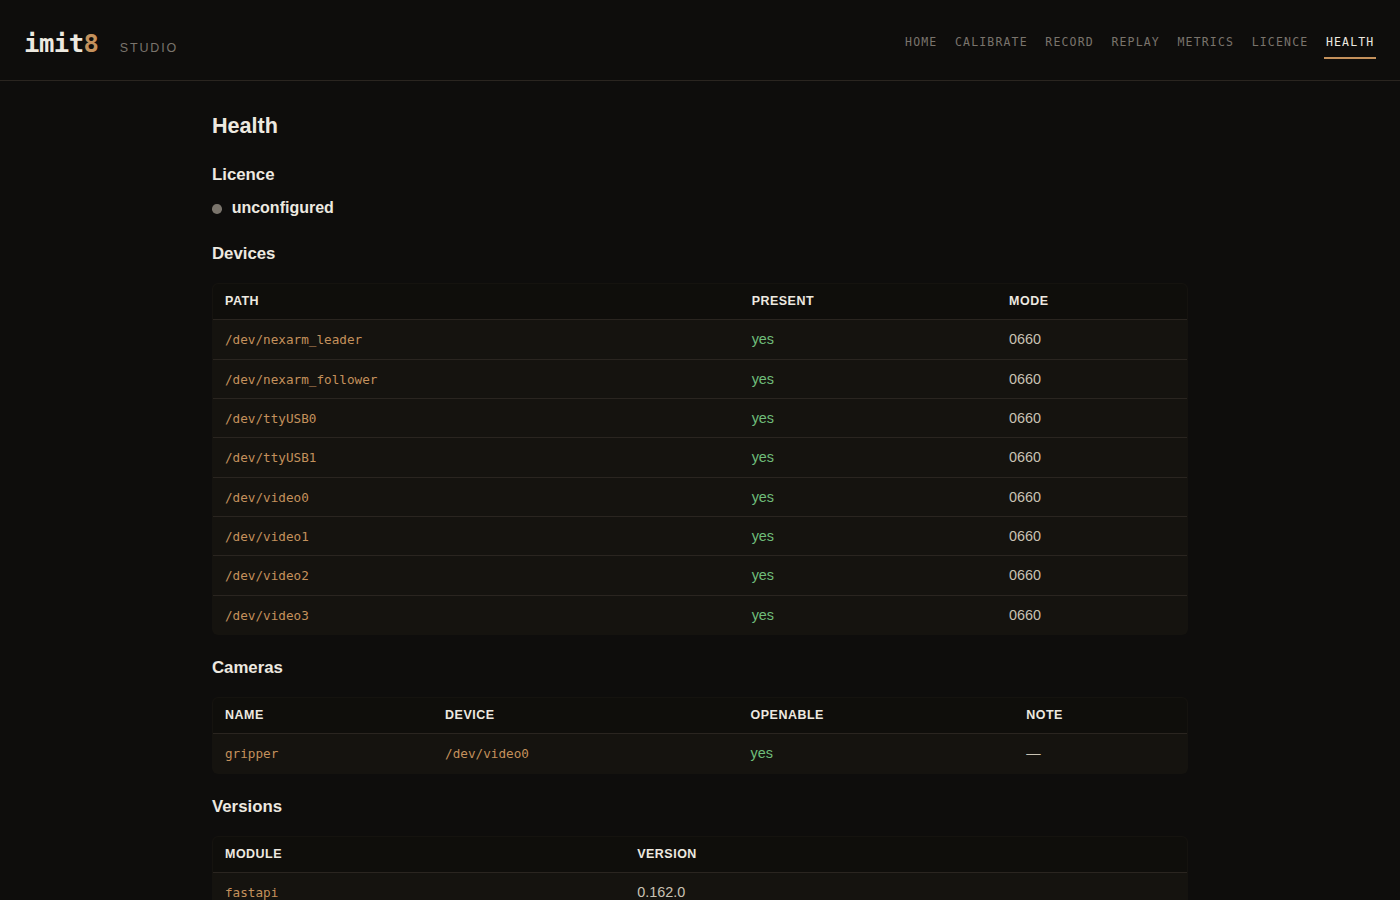
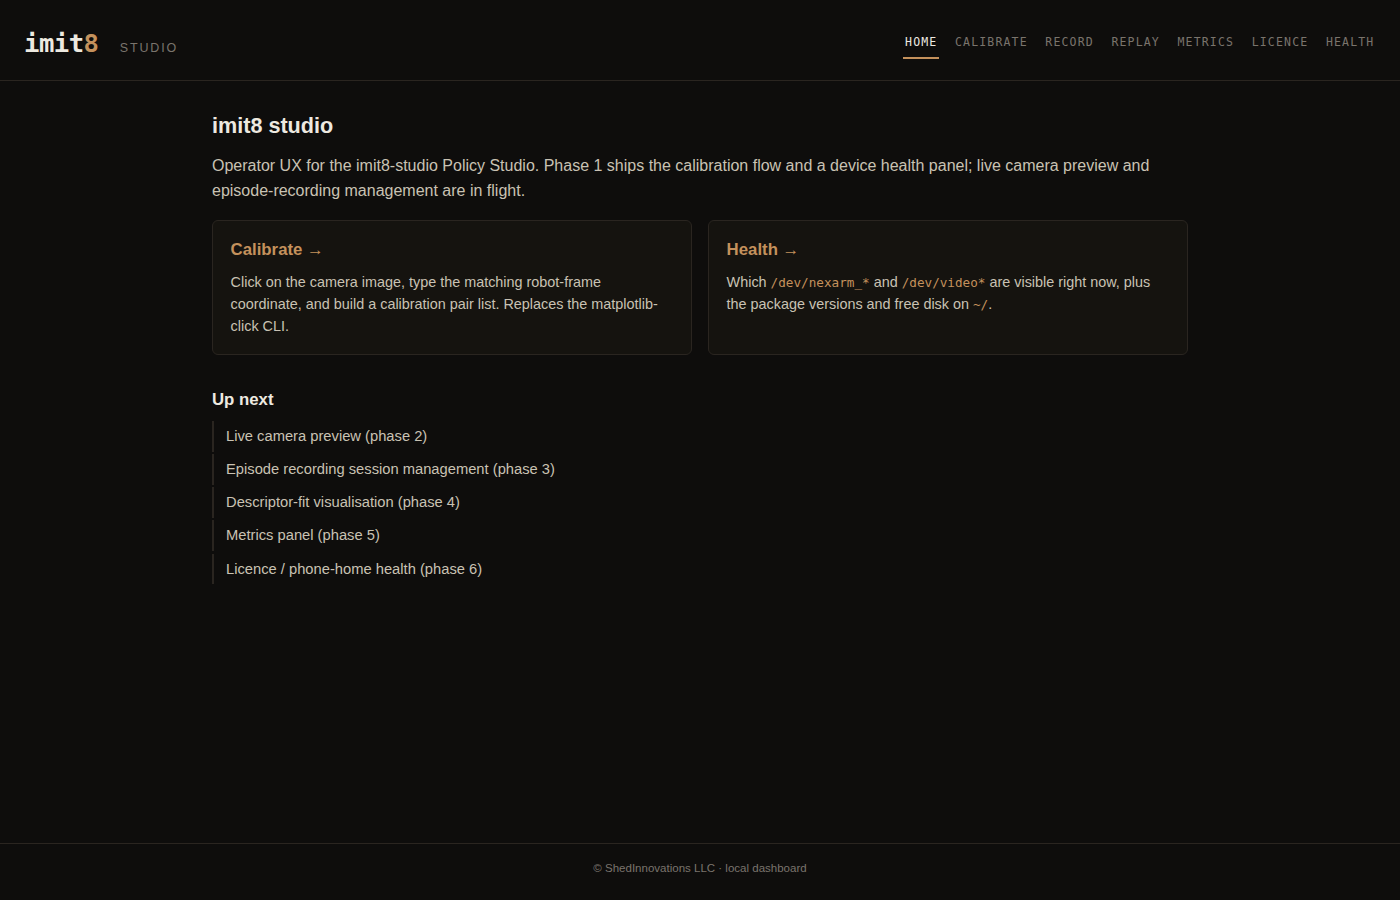
The browser dashboard (FastAPI + htmx + Alpine) sits in front of the CLIs: live MJPEG gripper + fixed-third-person preview, click-to-capture calibration with named save/load under ~/.imit8-studio/calibrations/ and an in-browser T_robot_from_world fit (Procrustes when you have 3+ pairs, translation-only otherwise), per-camera episode recording, replayable frames side-by-side with a top-down XY arc-fit overlay, per-episode metrics + cross-episode aggregate, client-side licence/phone-home with a 7-day grace window, and a device/version health page. Shared-password login (landing-matched hero) configurable via IMIT8_STUDIO_PASSWORD.
The dashboard, live on the bench
The dashboard is host-agnostic. The same tarball runs identically on the DGX Spark workstation (Linux + V4L2) or on a modern Mac (Apple Silicon + AVFoundation + the built-in CH340 driver). The IMIT8_STUDIO_IP_WHITELIST env lets any LAN-local operator click straight through to the live UX without the password gate:
Links work only from an IP in the whitelist. Off-LAN visitors land on the password gate.
Show the six-page dashboard tour — captured on the bench 2026-11-04
Captured 2026-11-04 on the DGX. The Mac view is pixel-identical; the only difference is the "HARDWARE ON" chip in the health strip, which shows the actual hostname so there’s no ambiguity which machine the devices above are physically attached to.
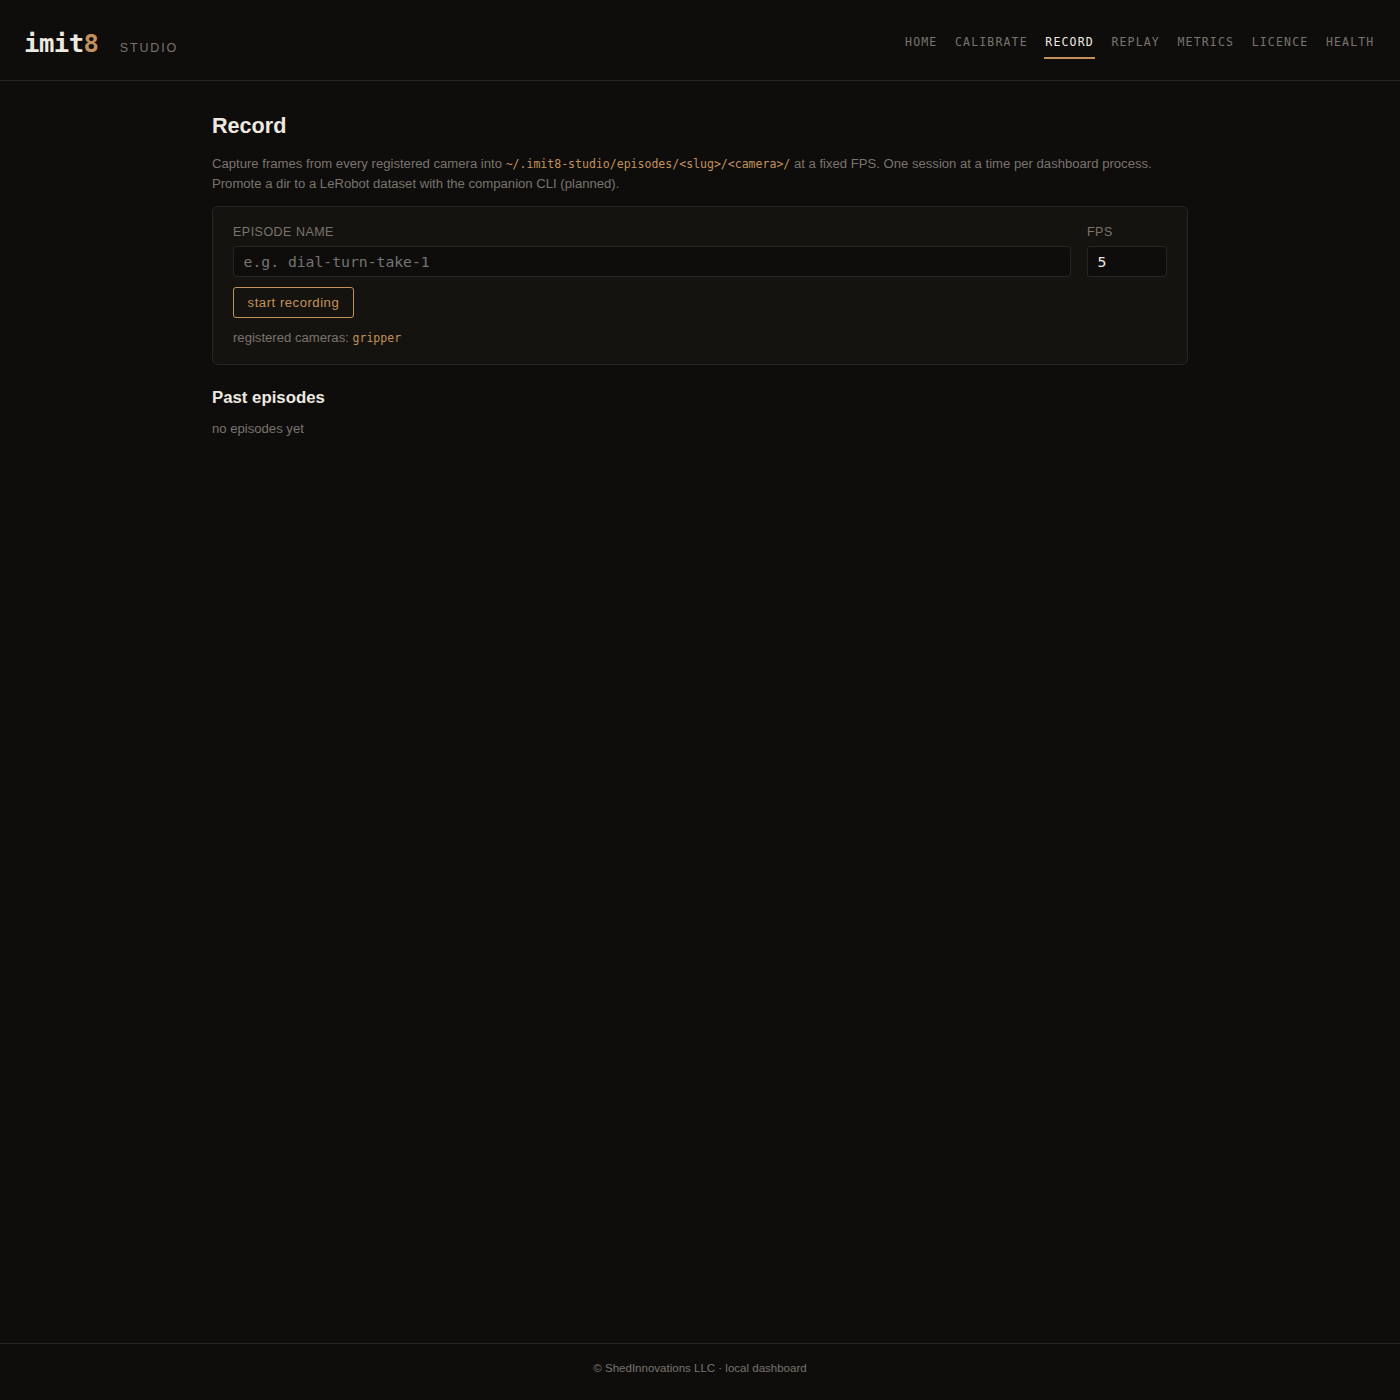
~/.imit8-studio/episodes/<task>/<take>/ at operator-chosen FPS.
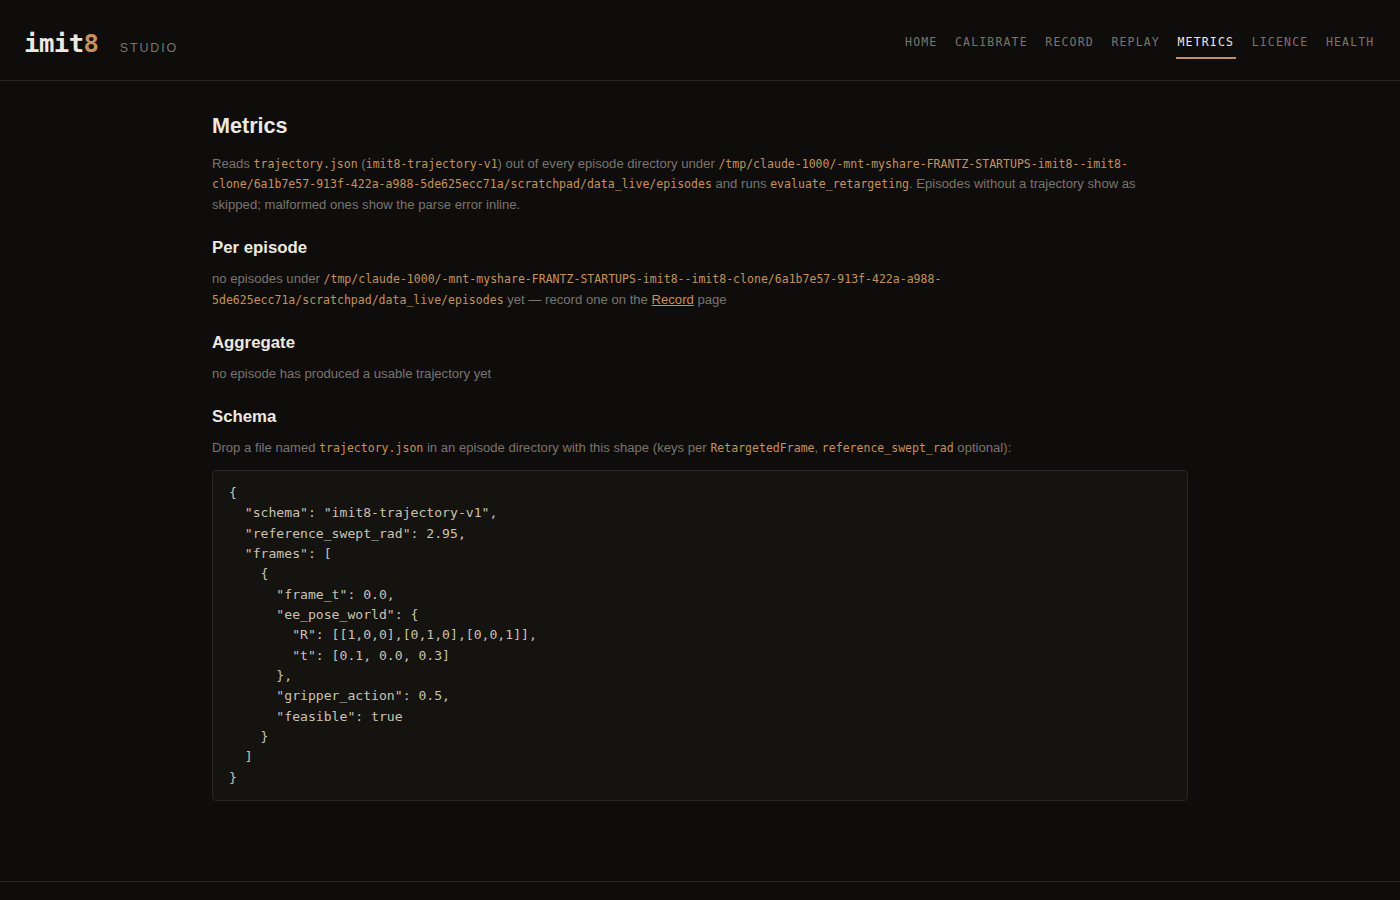
ik_feasibility_pct, swept_angle_error_rad, trajectory_jerk: per episode and aggregate.
Downloads
IP-restricted at the edge; if you reach a 403 Forbidden, email hello@imit8.ai with the address you’re connecting from.
Already on the bench LAN?
Skip the tarball and open the live operator dashboard on whichever host is serving:
DGX
·
Mac (wired)
·
Mac (wifi).
Whitelisted LAN IPs skip the password form automatically (IMIT8_STUDIO_IP_WHITELIST).
- • imit8-studio-0.2.0-alpha4.tar.gz (5.3 MB — includes
arm_sdk/) - • imit8-studio-0.2.0-alpha4.tar.gz.sha256
- • INSTALL.md (install instructions)
- • README.md (what’s in the box)
- • CHANGELOG.md (what’s new since 0.1.0)
Previous drops still available: 0.2.0-alpha3 (140 KB, no arm_sdk) · 0.2.0-alpha2 (134 KB) · 0.2.0-alpha1 (131 KB) · 0.1.0 (50 KB).
What ships
The typed PoseStage/DepthStage/Retargeter protocols; the ParallelJawRetargeter for xArm 6 + Hiwonder NexArm; Savitzky-Golay + SLERP trajectory smoothing; the contact-point-click calibration CLI and the browser dashboard’s read from arm button (LeRobot NexArmFollower + pytorch_kinematics FK); the arc-descriptor fit for the knob-turn task family; the three-metric evaluation harness; round-trippable imit8-trajectory-v1 dump/load (imit8.retargeting.trajectory_io); the six-page operator dashboard; AES-256-GCM + PBKDF2 encrypted Layer-3 weight bundles with per-customer salt rotation; phone-home licence server (SQLite + FastAPI + admin CLI); and the Nuitka standalone build recipe for the three compiled runtime targets. 174 unit + end-to-end tests, all green.
What doesn’t
Real-arm xArm SDK readback (the stdin CLI is still there; the NexArm readback is wired to the dashboard already), a bench-run Nuitka compile of the three targets (the recipe is in imit8.studio.build; the actual compile runs on the release machine), the one-task hero demo video, and the two preprints on arXiv (held behind patent review on the composition pattern + per-family descriptors). See the roadmap for the v0.2.0+ path and CHANGELOG.md inside the tarball for the shipping history.